i2RT DF160 Camera
Widest view in the lineup
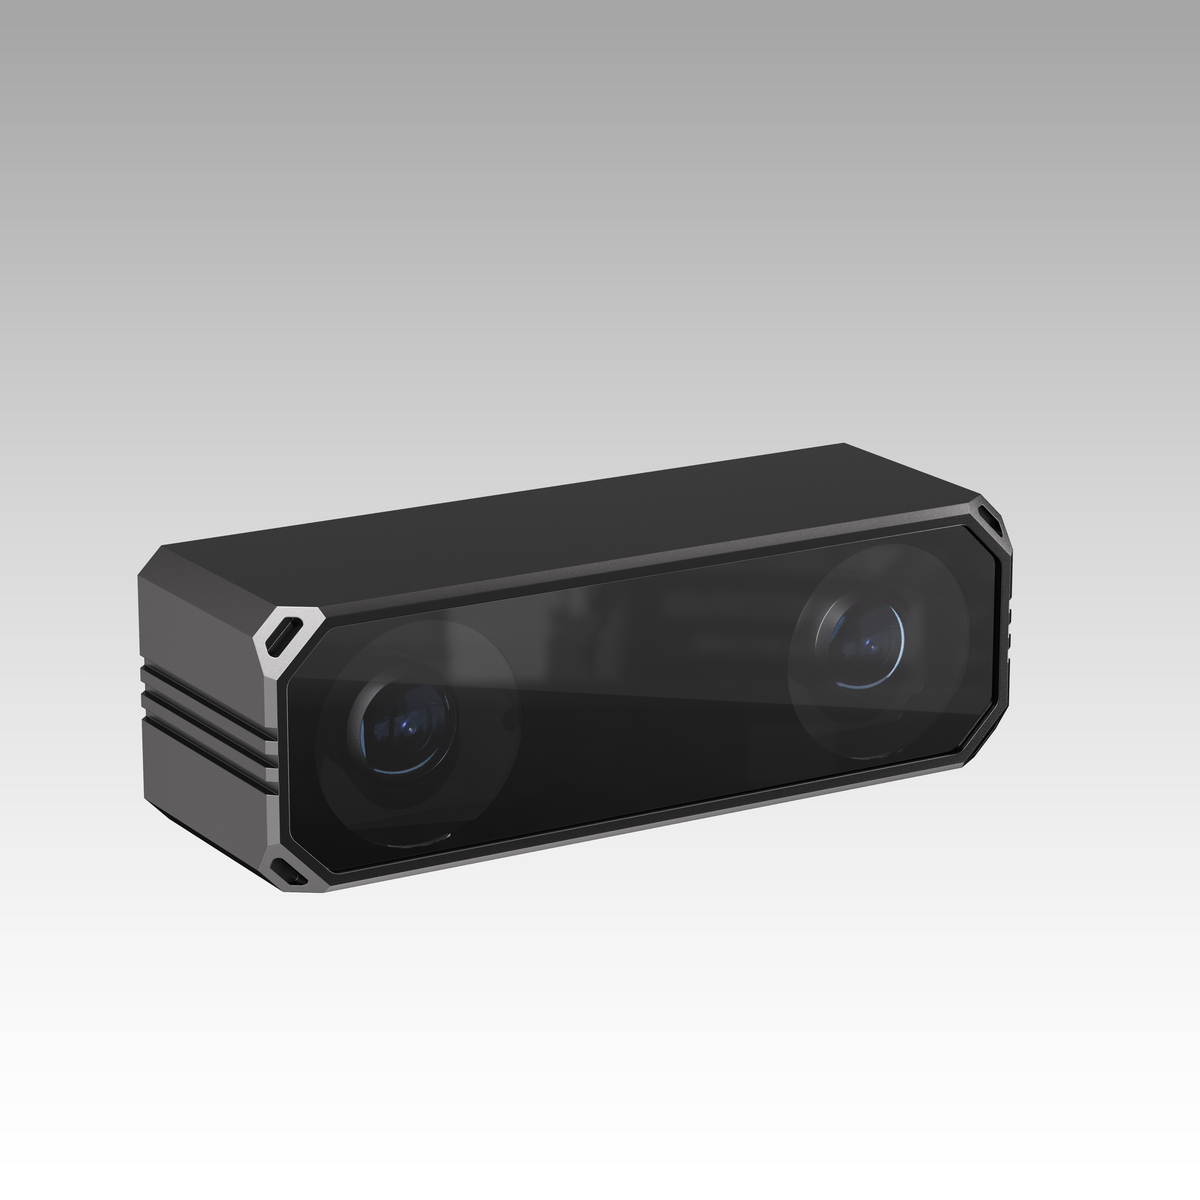
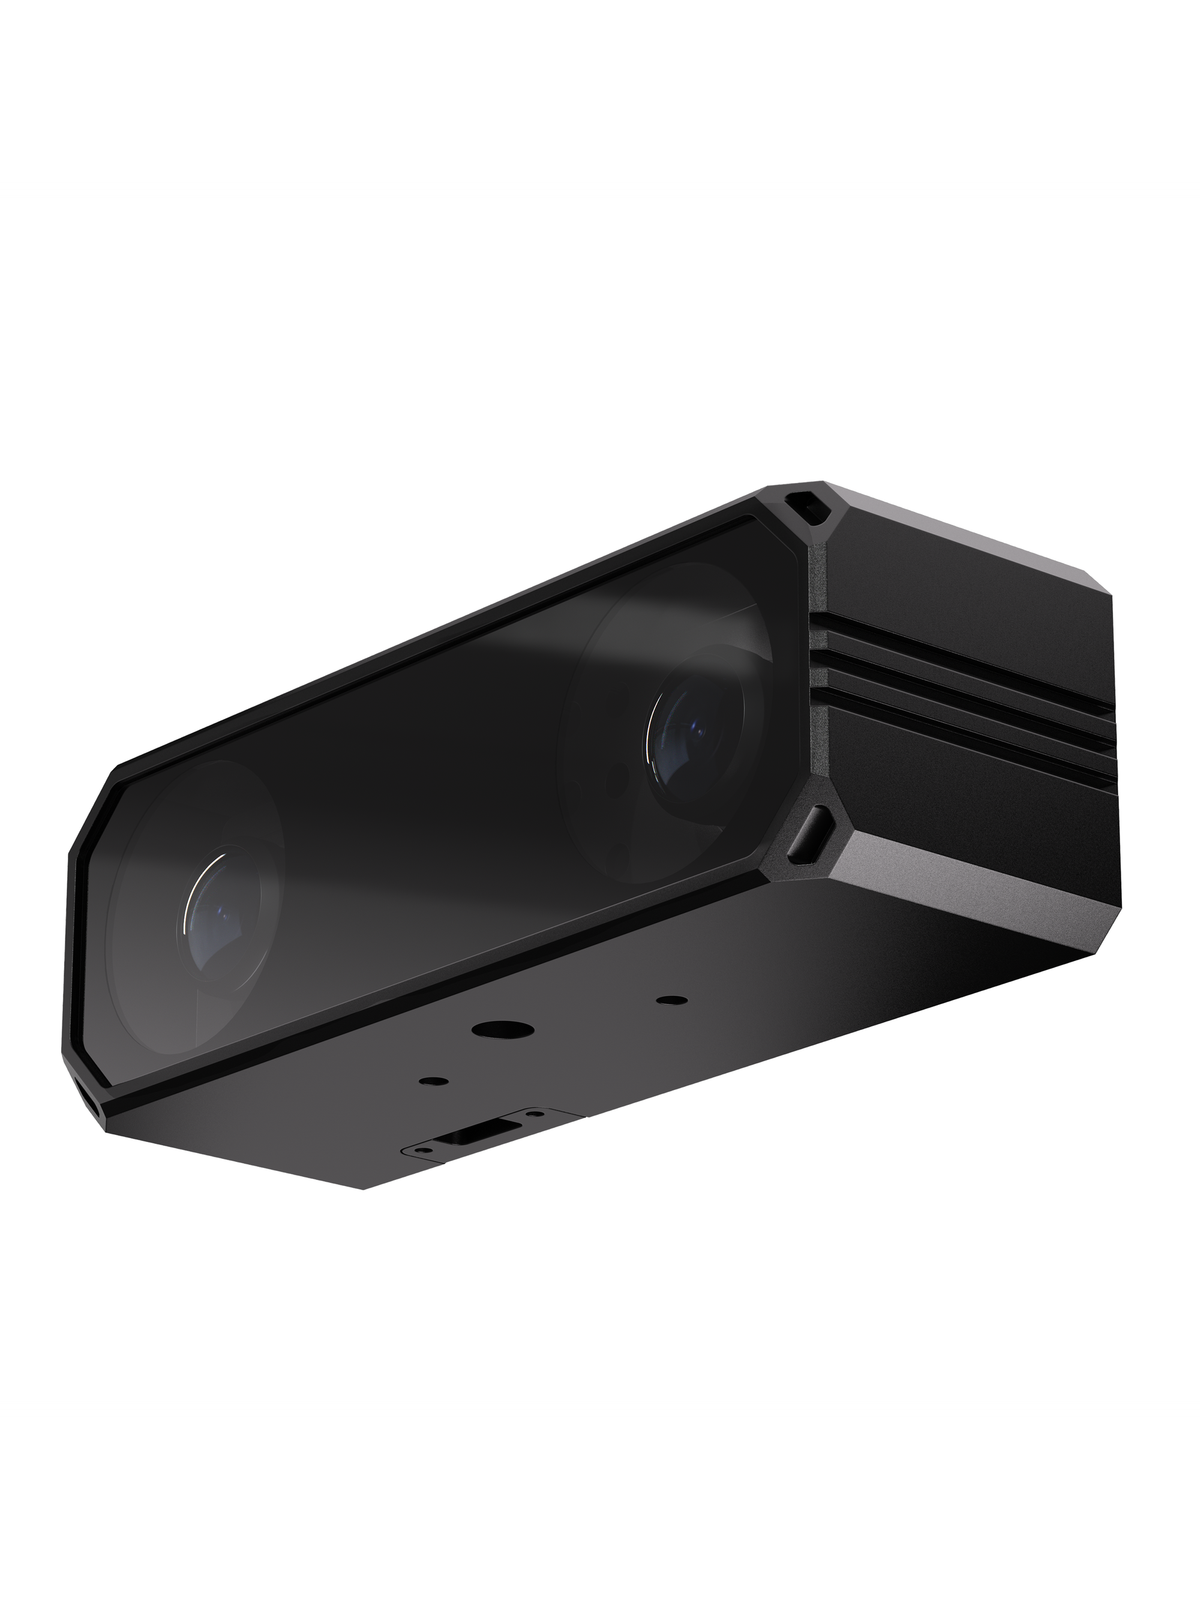
A dual-sensor USB 3.0 stereo camera with 160° diagonal coverage — significantly wider than typical stereo depth modules. For robot navigation, obstacle awareness, and scene-level capture, seeing as much of the scene as possible is what keeps a platform out of trouble. One camera covers the floor, the workspace, and the approach path in a single frame.
Global shutter, synchronized to 1µs
Both sensors are global shutter, and both are hardware-synchronized to within 1 microsecond. This is what makes stereo work on a moving robot. Rolling shutter skews each eye differently under motion; loosely synced sensors capture different instants entirely. Either one corrupts disparity and puts your depth estimate in the wrong place. The DF160 exposes both full frames at the same instant, so geometry stays valid at speed — on a mobile base under way, on a fast-moving arm, or on any platform where the scene doesn't hold still.
Depth where the robot works
The 60mm baseline — close to human eye spacing — puts the DF160's usable range squarely in the 0.3m to 3m band where manipulation and near-field navigation actually happen. Expect roughly 1cm accuracy at 1m and a few centimeters at 3m, with usable depth out to 5m. Not a long-range surveying sensor; a close-quarters spatial sensor tuned for the distances a robot arm and a mobile base care about.
Raw stereo, your pipeline
The DF160 delivers a synchronized 4000×1200 side-by-side stream at 60fps — 1920×1200 per eye — as standard UVC video. No proprietary SDK, no vendor lock-in, no waiting on a driver release. Feed it straight into OpenCV, libSGM, or your own matcher and keep full control over the depth stage: your choice of algorithm, your choice of tuning, your choice of where it runs.
Bright optics for dim rooms
An F1.8 aperture — the fastest in the i2RT camera lineup — with 37dB SNR and 70dB dynamic range. Stereo is less forgiving than mono: when one eye goes noisy, matching quality falls off with it. The DF160 keeps both eyes clean under indoor and warehouse lighting. (Note: as a passive stereo camera, the DF160 relies on scene texture. Featureless surfaces such as blank walls or uniform tabletops will yield sparse matches — add ambient texture or an external IR pattern projector for those environments.)
One cable, one pipeline
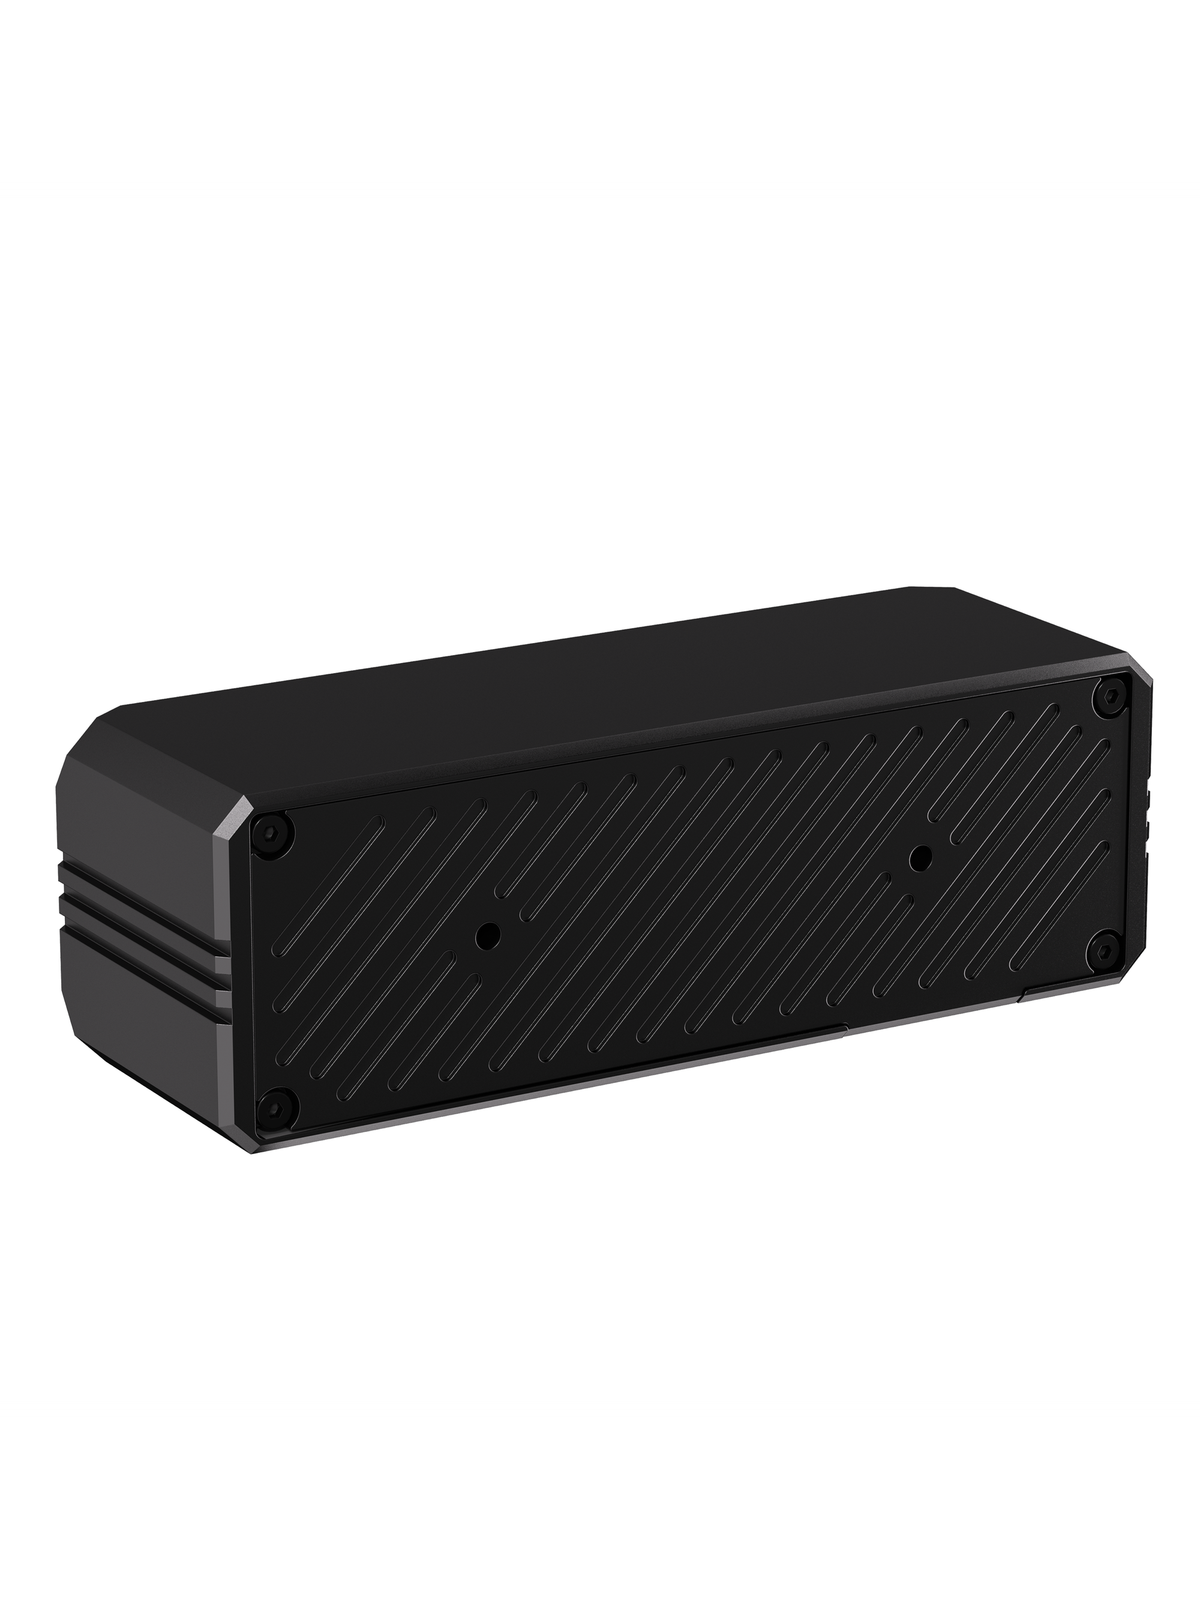
UVC-compliant on Windows, Linux (V4L2), macOS, and Android. At 32×97×32.8mm and 1.2W over a single Type-C cable, the DF160 mounts to a mast, frame rail, or mobile base head with no external power and no extra harness.
Key Specs
-Sensor: Dual 1/2.6" global shutter, 3µm × 3µm pixel size
-Shutter Type: Global shutter (both sensors)
-Stereo Sync: Hardware-synchronized, 1µs accuracy
-Output Resolution: 4000 × 1200 @ 60fps MJPEG (side-by-side stereo, 1920 × 1200 per eye)
-Output Formats: MJPEG, YUV2 (YUYV)
-Interface: USB 3.0 (Type-C, 24-pin upright connector)
-Lens: f=2.3mm, F1.8 aperture, 160° diagonal FOV, M12×P0.5 mount (×2)
-Baseline: 60 mm
-Depth Processing: Host-side (raw stereo output, no onboard depth engine)
-SNR: 37dB / Dynamic Range: 70dB
-Auto Features: AEC, AWB, AGC supported
-Power: 5V USB, 240mA (approx. 1.2W)
-Dimensions: 32mm × 97mm × 32.8mm
-Cable: 2M standard
-Operating Temp: 0°C to 60°C
-OS Support: Windows 10/11, Linux (kernel 2.6.26+, UVC/V4L2), macOS 11+, Android 8+
Click here for more information.
- Regular price
- $349.00
- Sale price
- $349.00
- Regular price
-
Couldn't load pickup availability